robotics
A 281-Gram Robot Jumped 7.6 Meters Without a Spring
A fabric-wrap transmission kept a small motor near peak power through a 190-millisecond push-off.
Summary
A fabric-wrap transmission kept a small motor near peak power through a 190-millisecond push-off.
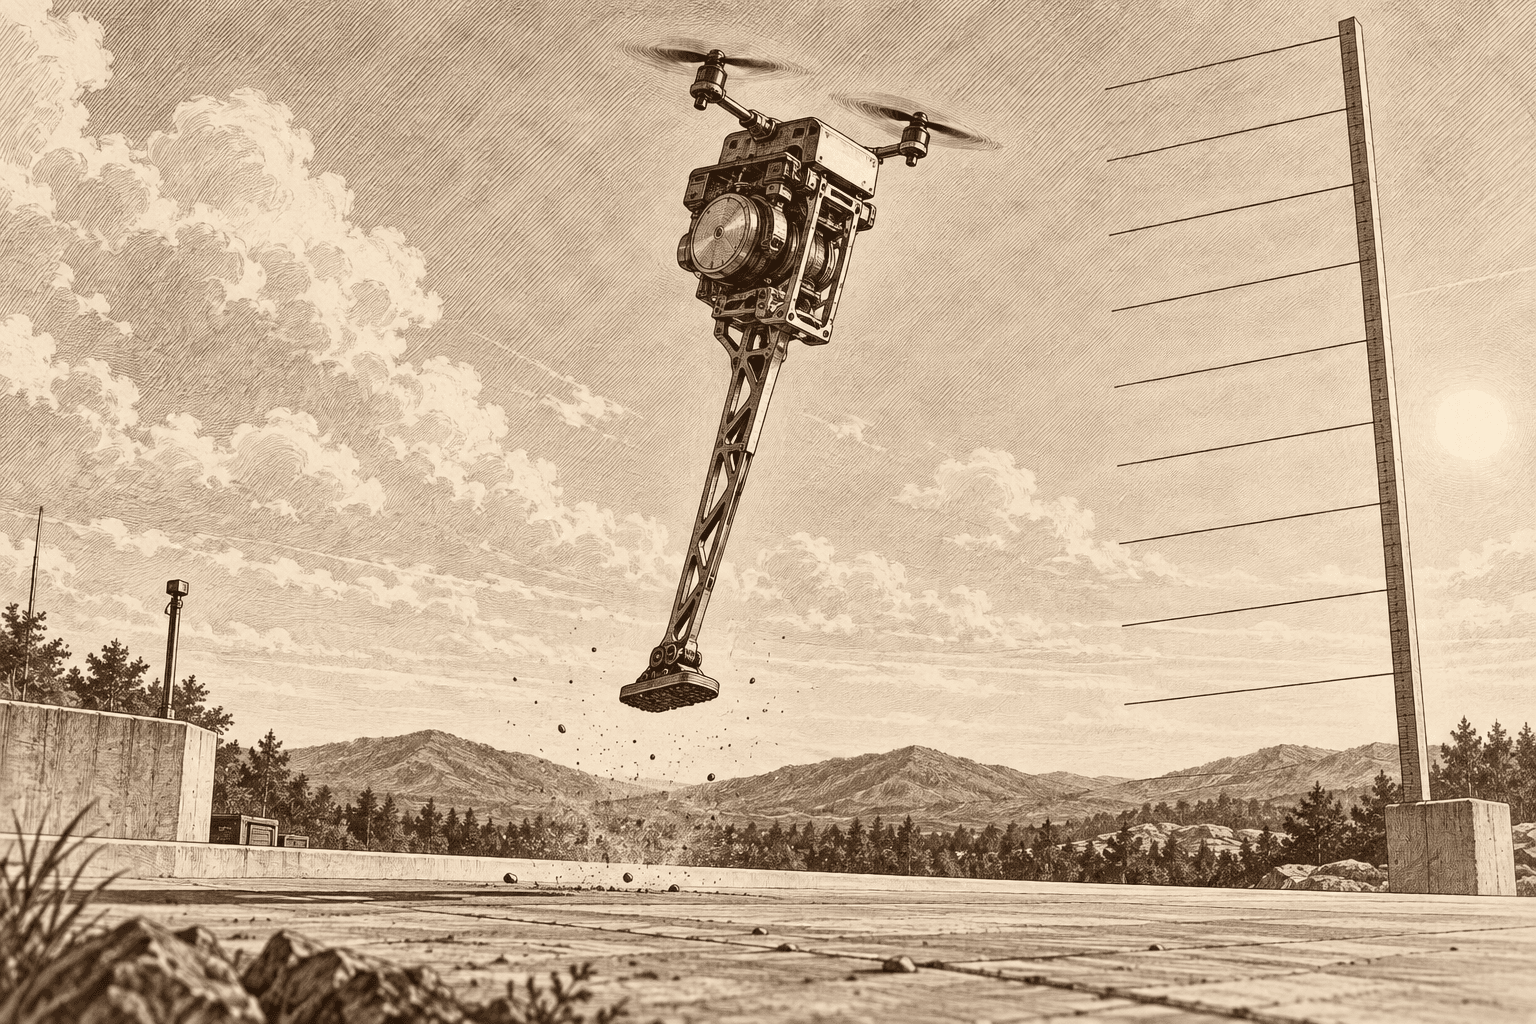
A long-legged monopedal robot reached a reported 7.6-meter vertical jump with a stance phase lasting 190 milliseconds. The 281-gram machine stores no energy in a spring; instead, a fabric-wrap direct-drive transmission changes mechanical advantage through the stroke so a small electric motor can stay near peak output while the leg resists buckling. Small propellers in the top module control orientation on the ground and in flight, using the long leg as a moment arm. The team demonstrated vertical, tilted and attitude-controlled jumps outdoors. The highest-jump comparison is the authors' claim for electrically actuated, spring-free systems, not a universal record across every jumping mechanism.
Why it matters
A fabric-wrap transmission kept a small motor near peak power through a 190-millisecond push-off.
Limits and context
- The highest-jump comparison is the authors' claim for electrically actuated, spring-free systems, not a universal record across every jumping mechanism.
Key claims
A fabric-wrap transmission kept a small motor near peak power through a 190-millisecond push-off.
Qualification: The highest-jump comparison is the authors' claim for electrically actuated, spring-free systems, not a universal record across every jumping mechanism.
Evidence: source-2026-09-28-001
Sources
- arXiv preprint 2609.30530arXiv · primary research
Corrections
No corrections have been recorded for this story.