robotics
The Human Demonstrations Crossed Into the Robot
UMI-Bridge reached 91.7% mean success across three real-robot tasks by aligning action, not appearance.
Summary
UMI-Bridge reached 91.7% mean success across three real-robot tasks by aligning action, not appearance.
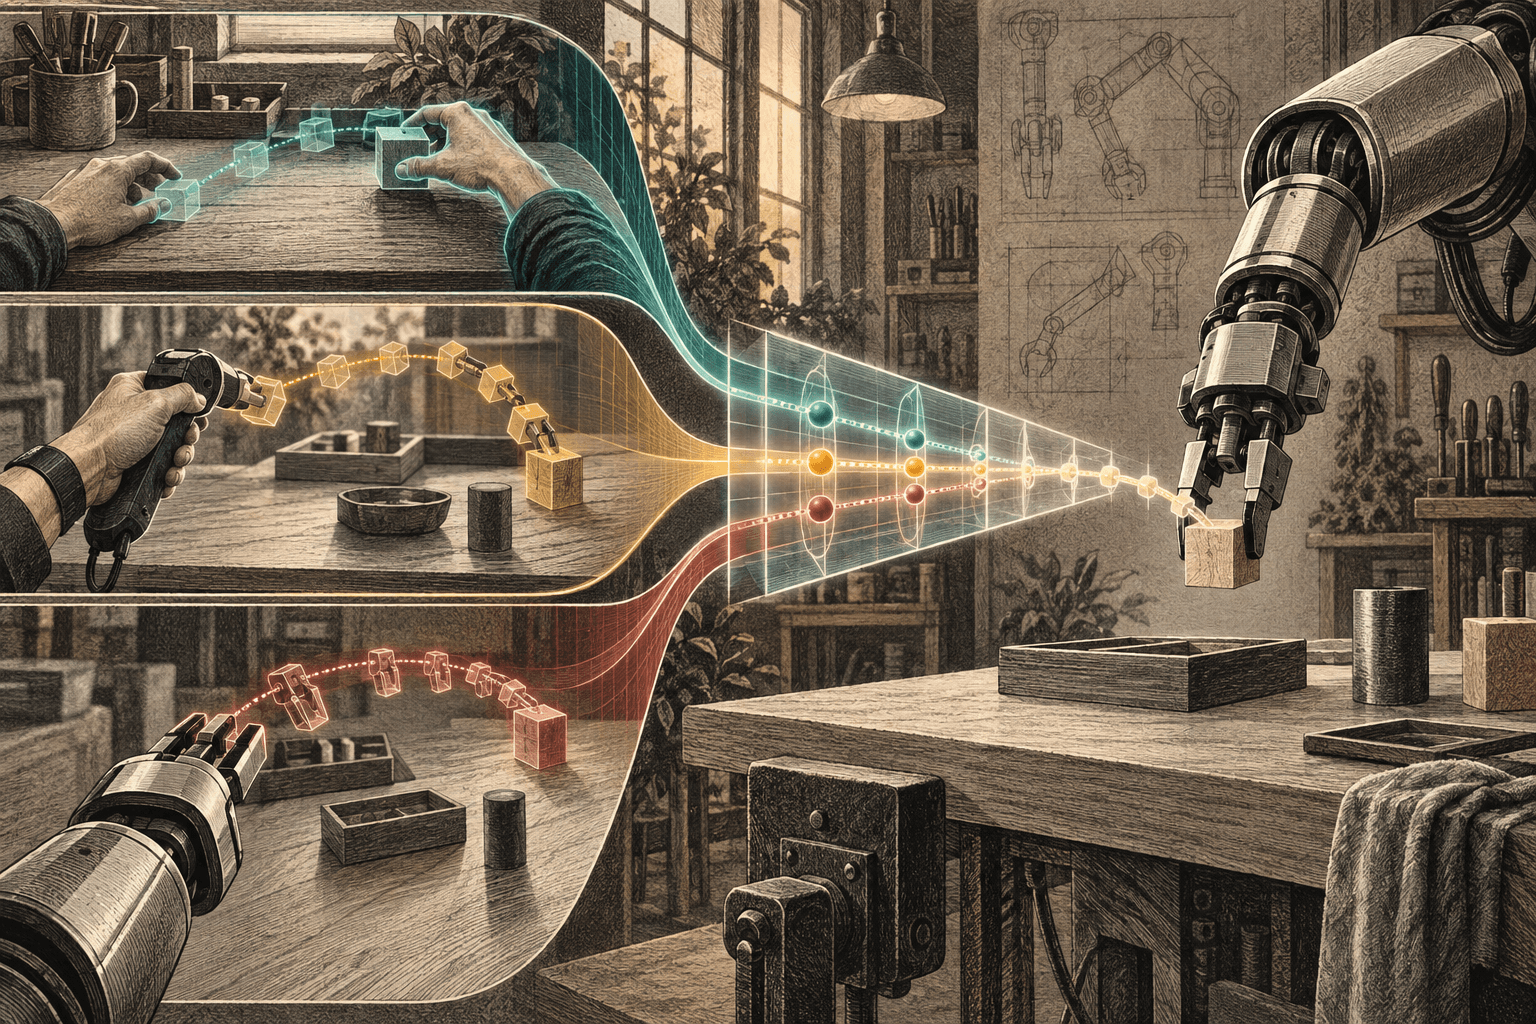
Human manipulation video is plentiful; robot demonstrations are not. UMI-Bridge uses handheld Universal Manipulation Interface data as an intermediate domain, anchoring a shared representation to end-effector motion and gripper behavior instead of pixel similarity. A dual-view latent action model learns from human data without robot demonstrations, then regularizes vision-language-action post-training while leaving the deployed policy architecture unchanged. Across three real-robot tasks, the method reported 91.7% mean success against 73.3% for matched naive co-training. With one quarter of the robot demonstrations plus UMI data, it exceeded a full-data robot-only baseline on two efficiency tasks; two further tasks reached 85% and 90% without task-specific robot demonstrations.
Why it matters
UMI-Bridge reached 91.7% mean success across three real-robot tasks by aligning action, not appearance.
Limits and context
- Human manipulation video is plentiful; robot demonstrations are not.
- With one quarter of the robot demonstrations plus UMI data, it exceeded a full-data robot-only baseline on two efficiency tasks; two further tasks reached 85% and 90% without task-specific robot demonstrations.
Key claims
UMI-Bridge reached 91.7% mean success across three real-robot tasks by aligning action, not appearance.
Qualification: Human manipulation video is plentiful; robot demonstrations are not.
Evidence: source-2026-09-17-001
Sources
- arXiv preprint 2609.18232arXiv · primary research
Corrections
No corrections have been recorded for this story.