robotics
A Robot Mapped Space Structures Without Markers
The inspection stack combined RGB-D, thermal and lidar sensing on a Kinova arm for large-structure reconstruction.
Summary
The inspection stack combined RGB-D, thermal and lidar sensing on a Kinova arm for large-structure reconstruction.
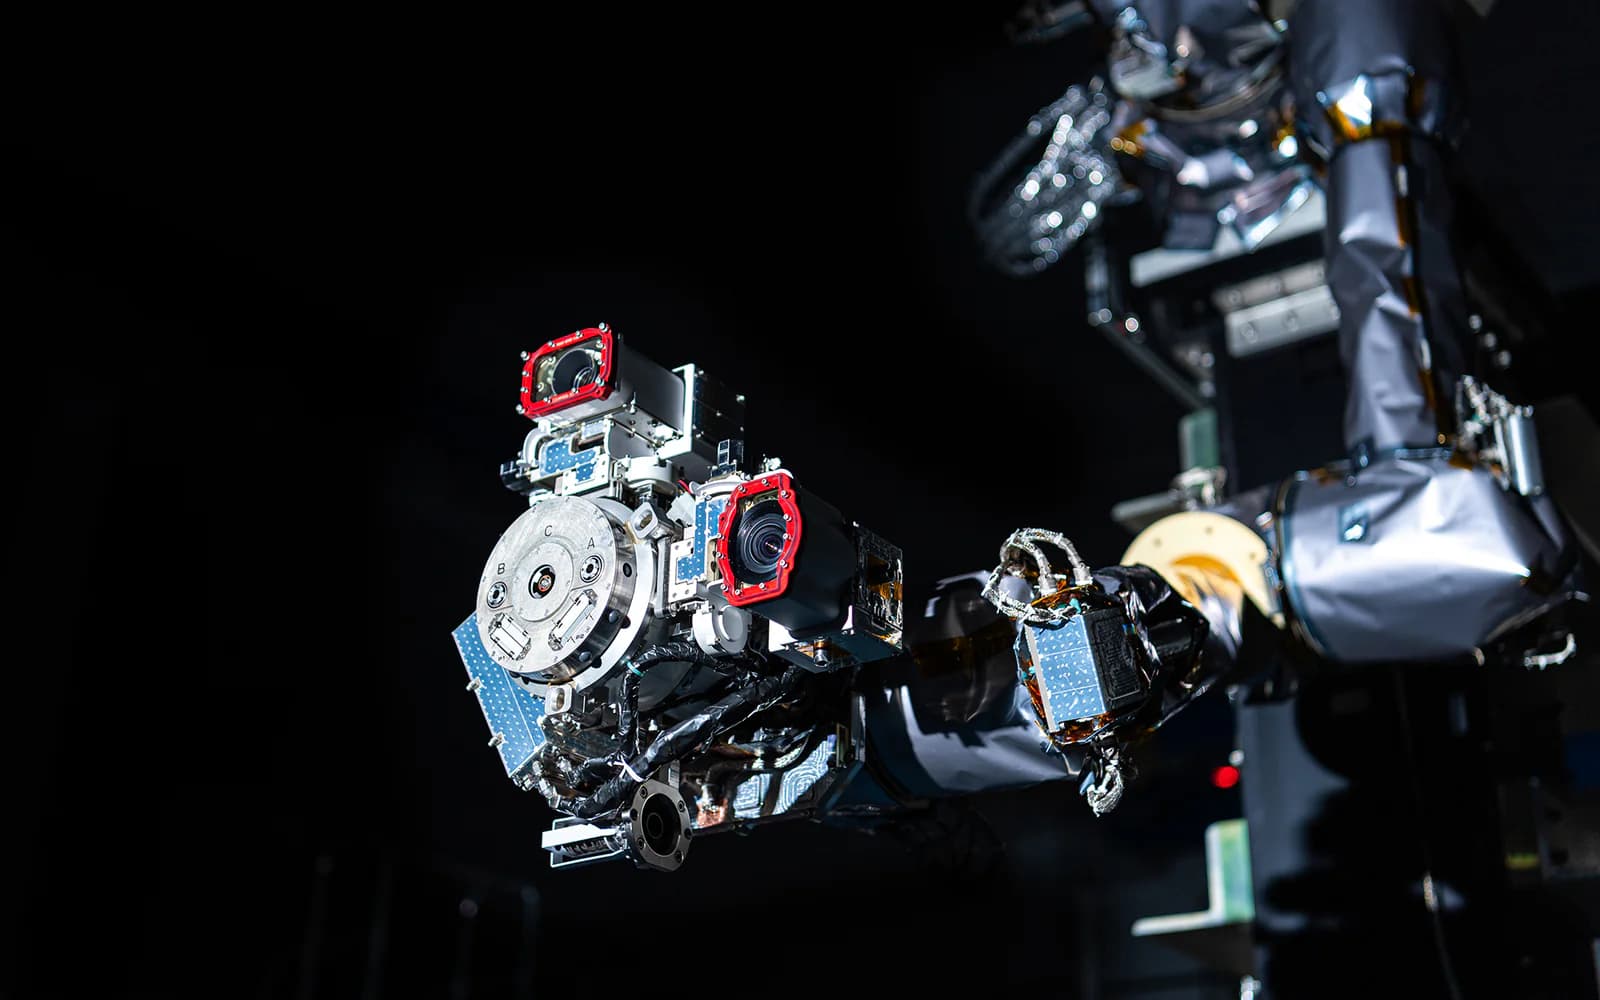
Researchers built a markerless multimodal inspection stack around a Kinova Gen2 arm, an RGB-D camera, a thermal camera and 2D lidar. The system plans viewpoints and motion while synchronizing the sensor streams into geometric and thermal reconstructions. Gazebo studies and preliminary laboratory work produced usable models in the reported setup; this iSpaRo-accepted paper is an early inspection result, not an on-orbit demonstration.
Why it matters
The inspection stack combined RGB-D, thermal and lidar sensing on a Kinova arm for large-structure reconstruction.
Limits and context
- Gazebo studies and preliminary laboratory work produced usable models in the reported setup; this iSpaRo-accepted paper is an early inspection result, not an on-orbit demonstration.
Key claims
The inspection stack combined RGB-D, thermal and lidar sensing on a Kinova arm for large-structure reconstruction.
Qualification: Gazebo studies and preliminary laboratory work produced usable models in the reported setup; this iSpaRo-accepted paper is an early inspection result, not an on-orbit demonstration.
Evidence: source-2026-09-27-013
Sources
- arXiv preprint 2609.29644arXiv · primary research
Corrections
No corrections have been recorded for this story.