robotics
The Robot Was Designed as One System
Pixel co-designs a low-cost wheeled humanoid, human and robot demonstrations, whole-body control and language-conditioned policy learning around the same manipulation stack.
Summary
Pixel co-designs a low-cost wheeled humanoid, human and robot demonstrations, whole-body control and language-conditioned policy learning around the same manipulation stack.
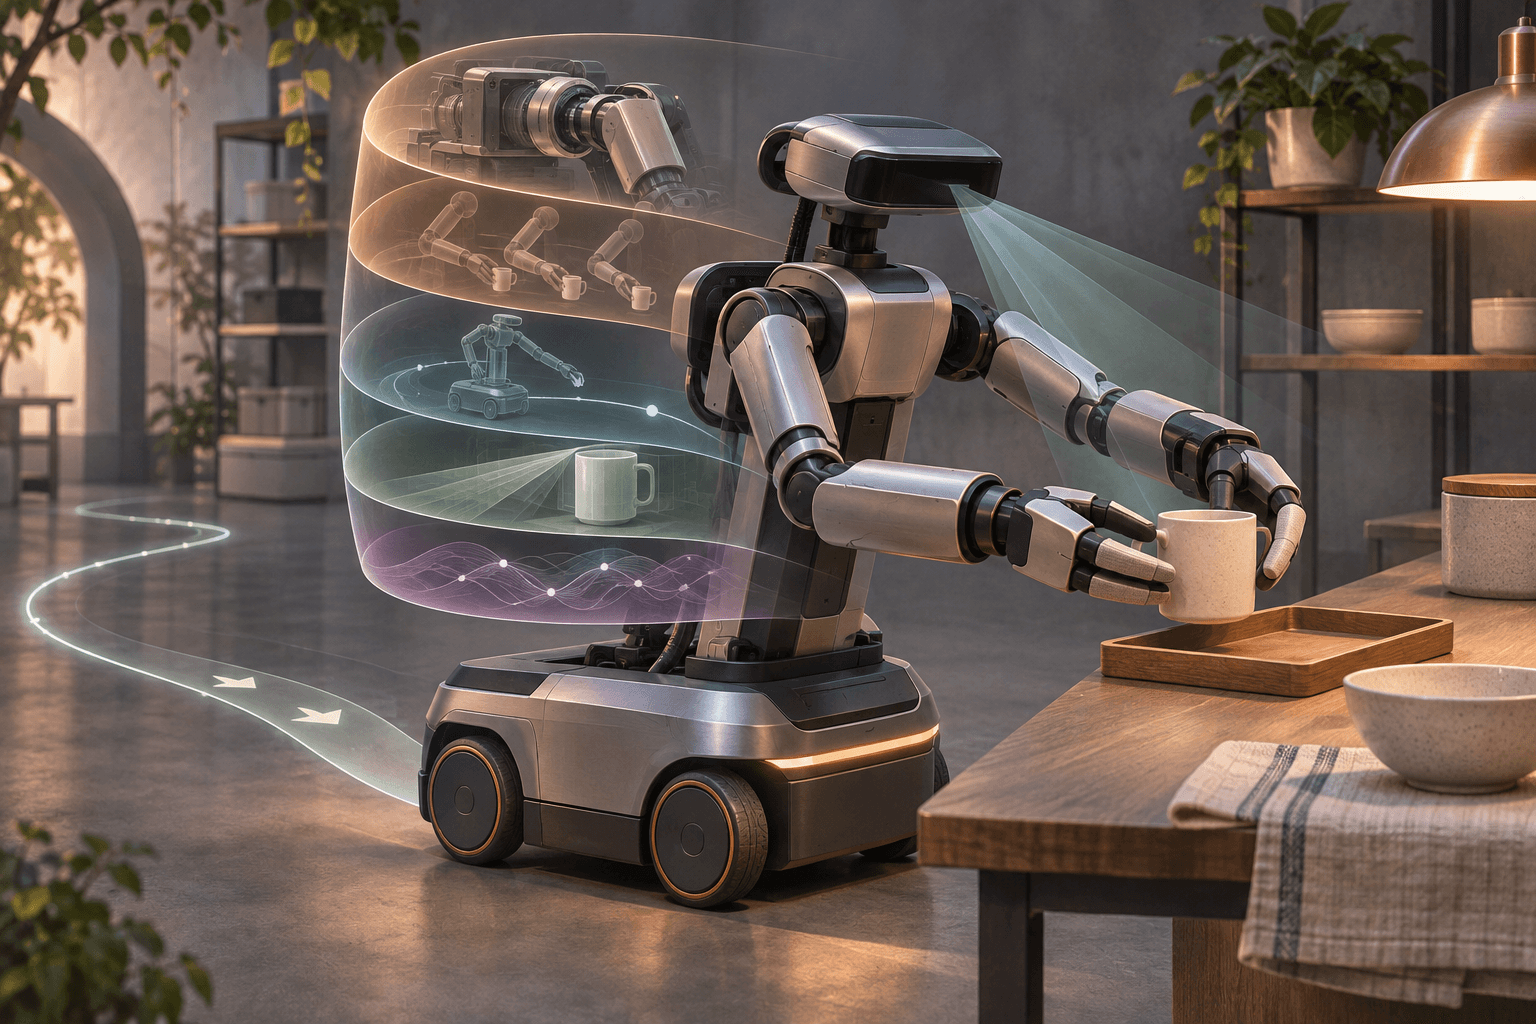
General-purpose mobile manipulation is usually assembled from hardware, teleoperation, control and learning components developed on separate assumptions. Pixel treats those interfaces as the design problem. The system combines a low-cost wheeled humanoid with human-aligned kinematics and compliant grippers, several teleoperation and robot-free human-data collection methods, a unified whole-body controller and one policy-learning pipeline across human and robot demonstrations. A hierarchical layer adds language-conditioned visuomotor control for longer tasks. The paper evaluates hardware, collection and learning together and demonstrates behaviors that require dexterity, active perception, navigation and coordinated whole-body motion. The result is an integrated research platform rather than a claim of solved household autonomy: the abstract does not report a universal success rate, deployment safety record or comparison proving that co-design wins on every task. Its contribution is the alignment of the stack and the evidence that the complete system can execute varied mobile-manipulation behaviors.
Why it matters
Pixel co-designs a low-cost wheeled humanoid, human and robot demonstrations, whole-body control and language-conditioned policy learning around the same manipulation stack.
Limits and context
- The result is an integrated research platform rather than a claim of solved household autonomy: the abstract does not report a universal success rate, deployment safety record or comparison proving that co-design wins on every task.
Key claims
Pixel co-designs a low-cost wheeled humanoid, human and robot demonstrations, whole-body control and language-conditioned policy learning around the same manipulation stack.
Qualification: The result is an integrated research platform rather than a claim of solved household autonomy: the abstract does not report a universal success rate, deployment safety record or comparison proving that co-design wins on every task.
Evidence: source-2026-11-03-002
Sources
- arXiv preprint 2611.03648, original v1arXiv · primary research
Corrections
No corrections have been recorded for this story.